Role
Design & Engineering Lead
Timeline
September 2026
Stack Tags
ESP32
Arduino
3D Printing
Stepper Motors
CAD Design
Belt Drive
GT2 Timing Belt
Stepper Motor
Embedded systems
Electronics
Firmware
Overview & Problem Statement
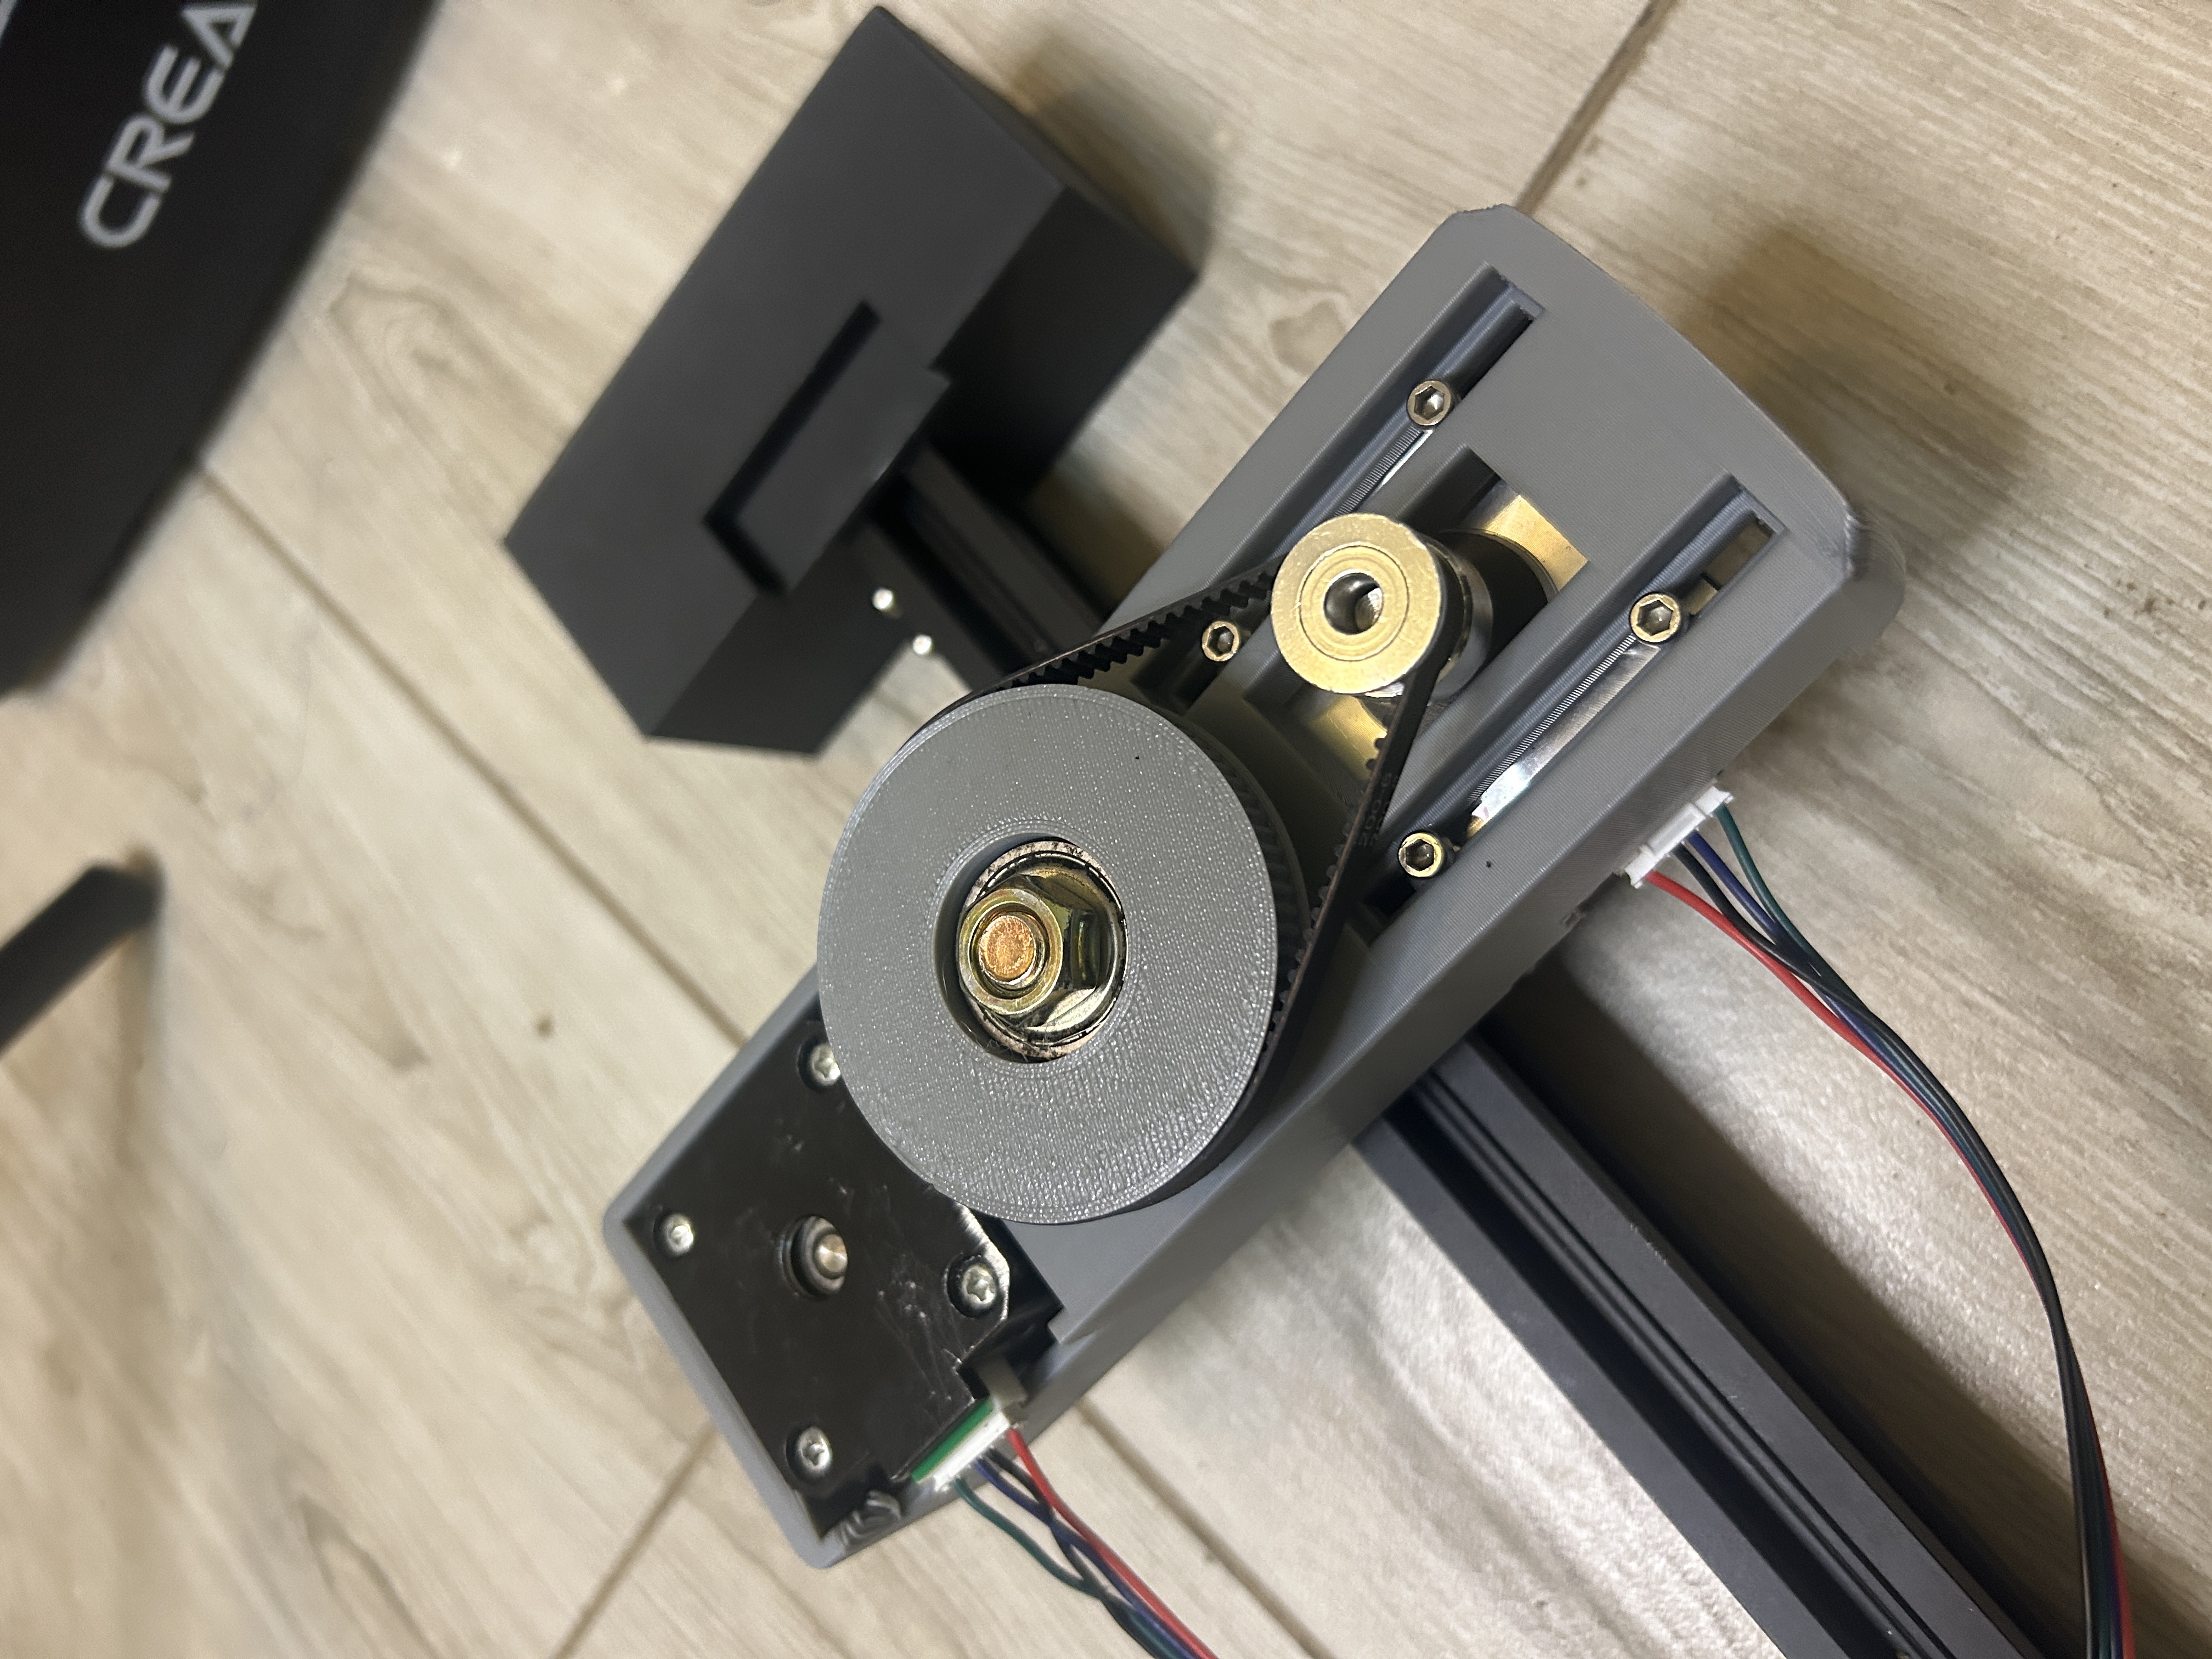
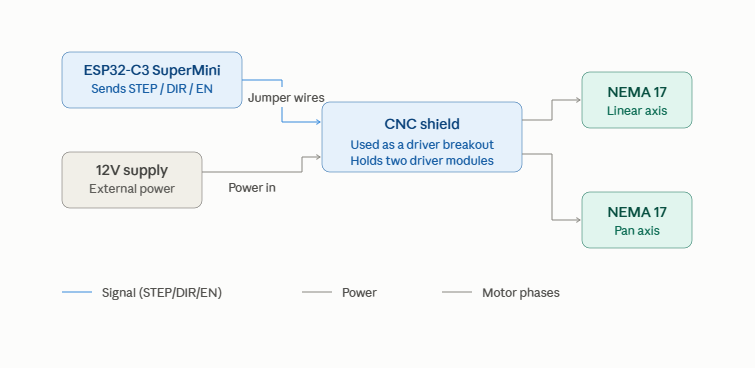
The rig moves horizontally along the 2020 aluminium extrusion and adds a pan axis, both driven by nea 17 steppers through 3D-printed GT2 pulleys Power comes from an external 12v supply feeding the CNC shield
System Architecture & Technical Approach
STEP/DIR/EN pins are jumpered from the ESP32-C3 Supermini directly to the CNC shield driver sockets. Everything structural is 3-D printed; T-nuts and cap screws handle mounting
Hardware & Software Implementation
// Dual-axis motion control — ESP32-C3 SuperMini + CNC shield (driver breakout mode)
// Linear axis + pan axis, both driven via STEP/DIR through AccelStepper

#include <AccelStepper.h>

#define LINEAR_STEP_PIN 4
#define LINEAR_DIR_PIN  5
#define PAN_STEP_PIN    6
#define PAN_DIR_PIN     7

AccelStepper linearAxis(AccelStepper::DRIVER, LINEAR_STEP_PIN, LINEAR_DIR_PIN);
AccelStepper panAxis(AccelStepper::DRIVER, PAN_STEP_PIN, PAN_DIR_PIN);

void setup() {
  linearAxis.setMaxSpeed(800);
  linearAxis.setAcceleration(400);

  panAxis.setMaxSpeed(400);
  panAxis.setAcceleration(200);
}

void loop() {
  linearAxis.runToNewPosition(2000);
  delay(500);
  panAxis.runToNewPosition(400);
  delay(500);
  linearAxis.runToNewPosition(0);
  delay(500);
  panAxis.runToNewPosition(0);
  delay(500);
}| Part | Qty | Notes |
|---|---|---|
| NEMA 17 | 2 | One on linear axis one for pan axis |
| CNC Shield | 1 | |
| ESP32-C3 Supermini | 1 | |
| 12v External power supply | 1 | |
| 2020 v-slot extrusion | 1 | Length depends on desired travel |
| GT2 Belts | ||
| GT2 Pulley 20 Teeth | ||
| 3D printed mounts | ||
| T-nuts | ||
| Jumper cables |
Key Challenges & Technical Trade-offs
The CNC Shield here works as a driver breakout board.
Results, Impact & Performance Metrics
Both axes move smoothly and hold position accurately across repeated test runs. The linear axis travels the full extrusion length without the belt skipping.
The pan rotates cleanly through its test range with no detected step loss.