Techkyman // Software & Embedded Systems Engineer
Architecting Software, Hardware, and AI-Driven Automation.
Building end-to-end web applications, real-time IoT systems, and automated workflows using modern engineering practices and AI-assisted workflows.
Tech Stack
The toolset behind every build — from firmware to the cloud dashboards that talk to it.
Web & Backend
Full-stack platforms & APIs
Embedded & Hardware
Firmware to physical I/O
AI & Infrastructure
AI-assisted workflows & deployment
Featured Projects
Real builds spanning the full stack — web platforms, embedded hardware, and AI-driven automation.
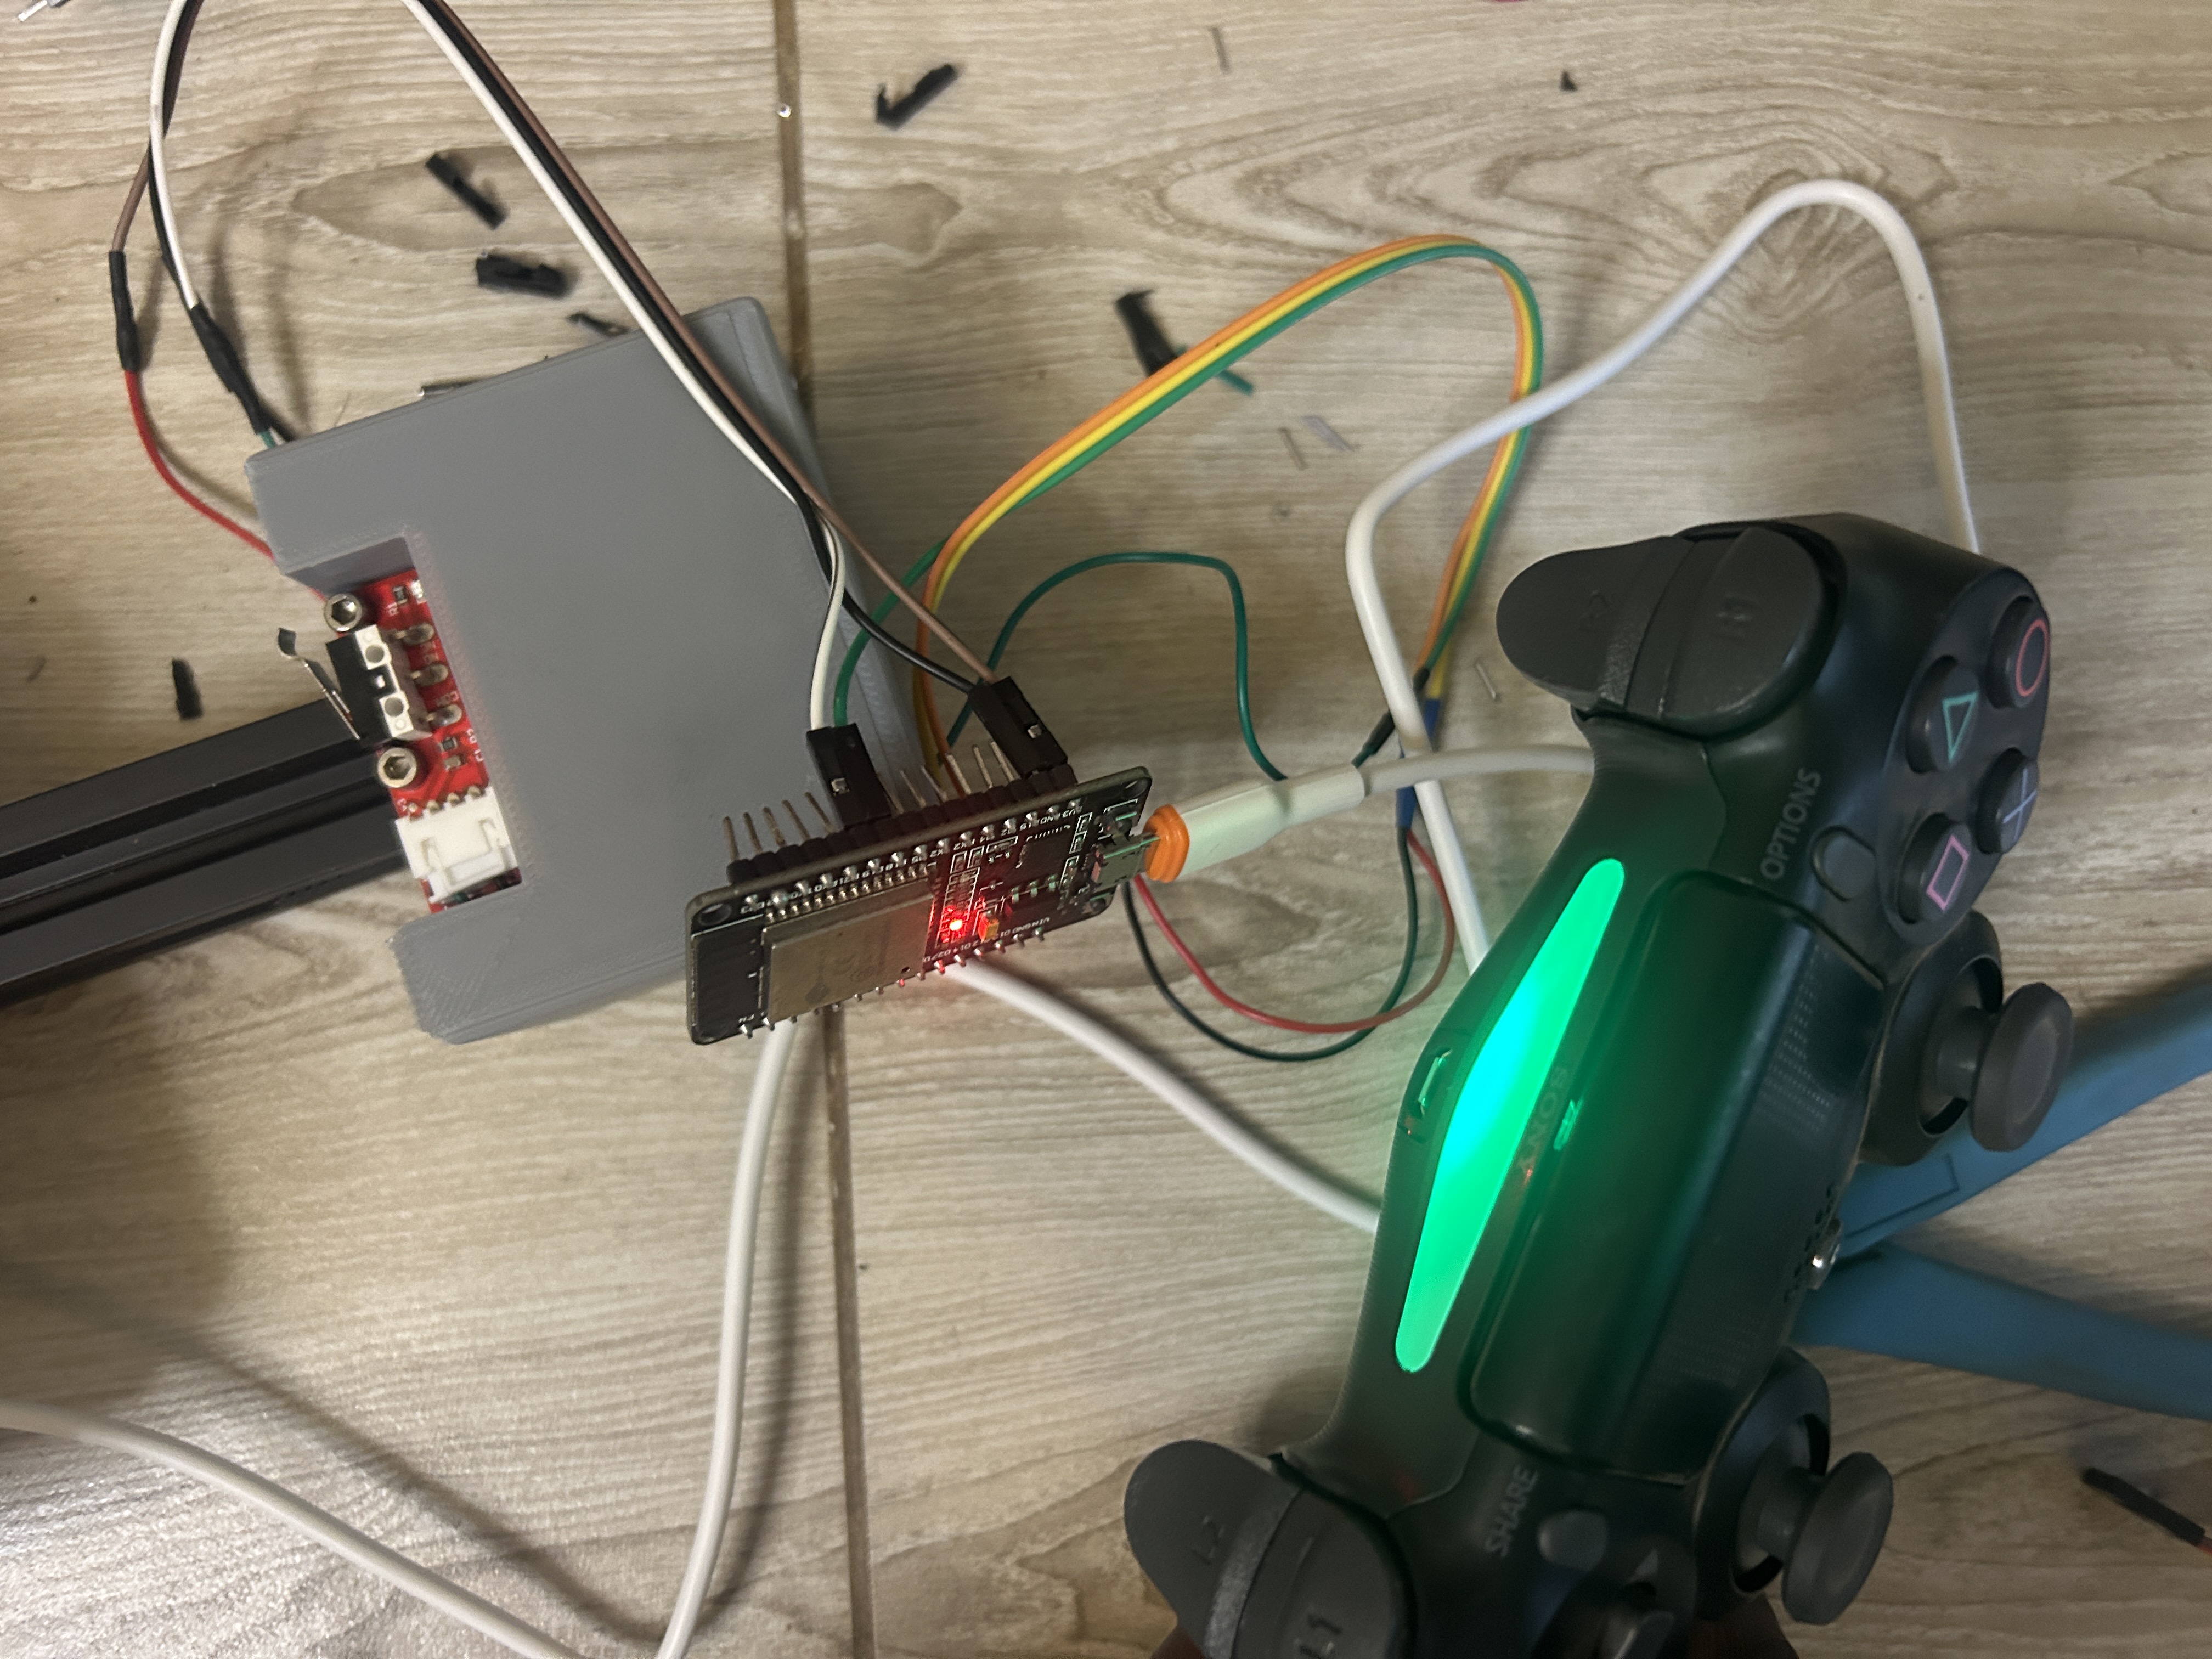
How to Connect a PS4 Controller to an ESP32 Dev Kit with Bluepad32
Pair a PS4 controller to an ESP32 dev kit over Bluetooth using the bluepad library, then read button presses, analog sticks and D-Pad input in real time No extra Bluetooth hardware needed.
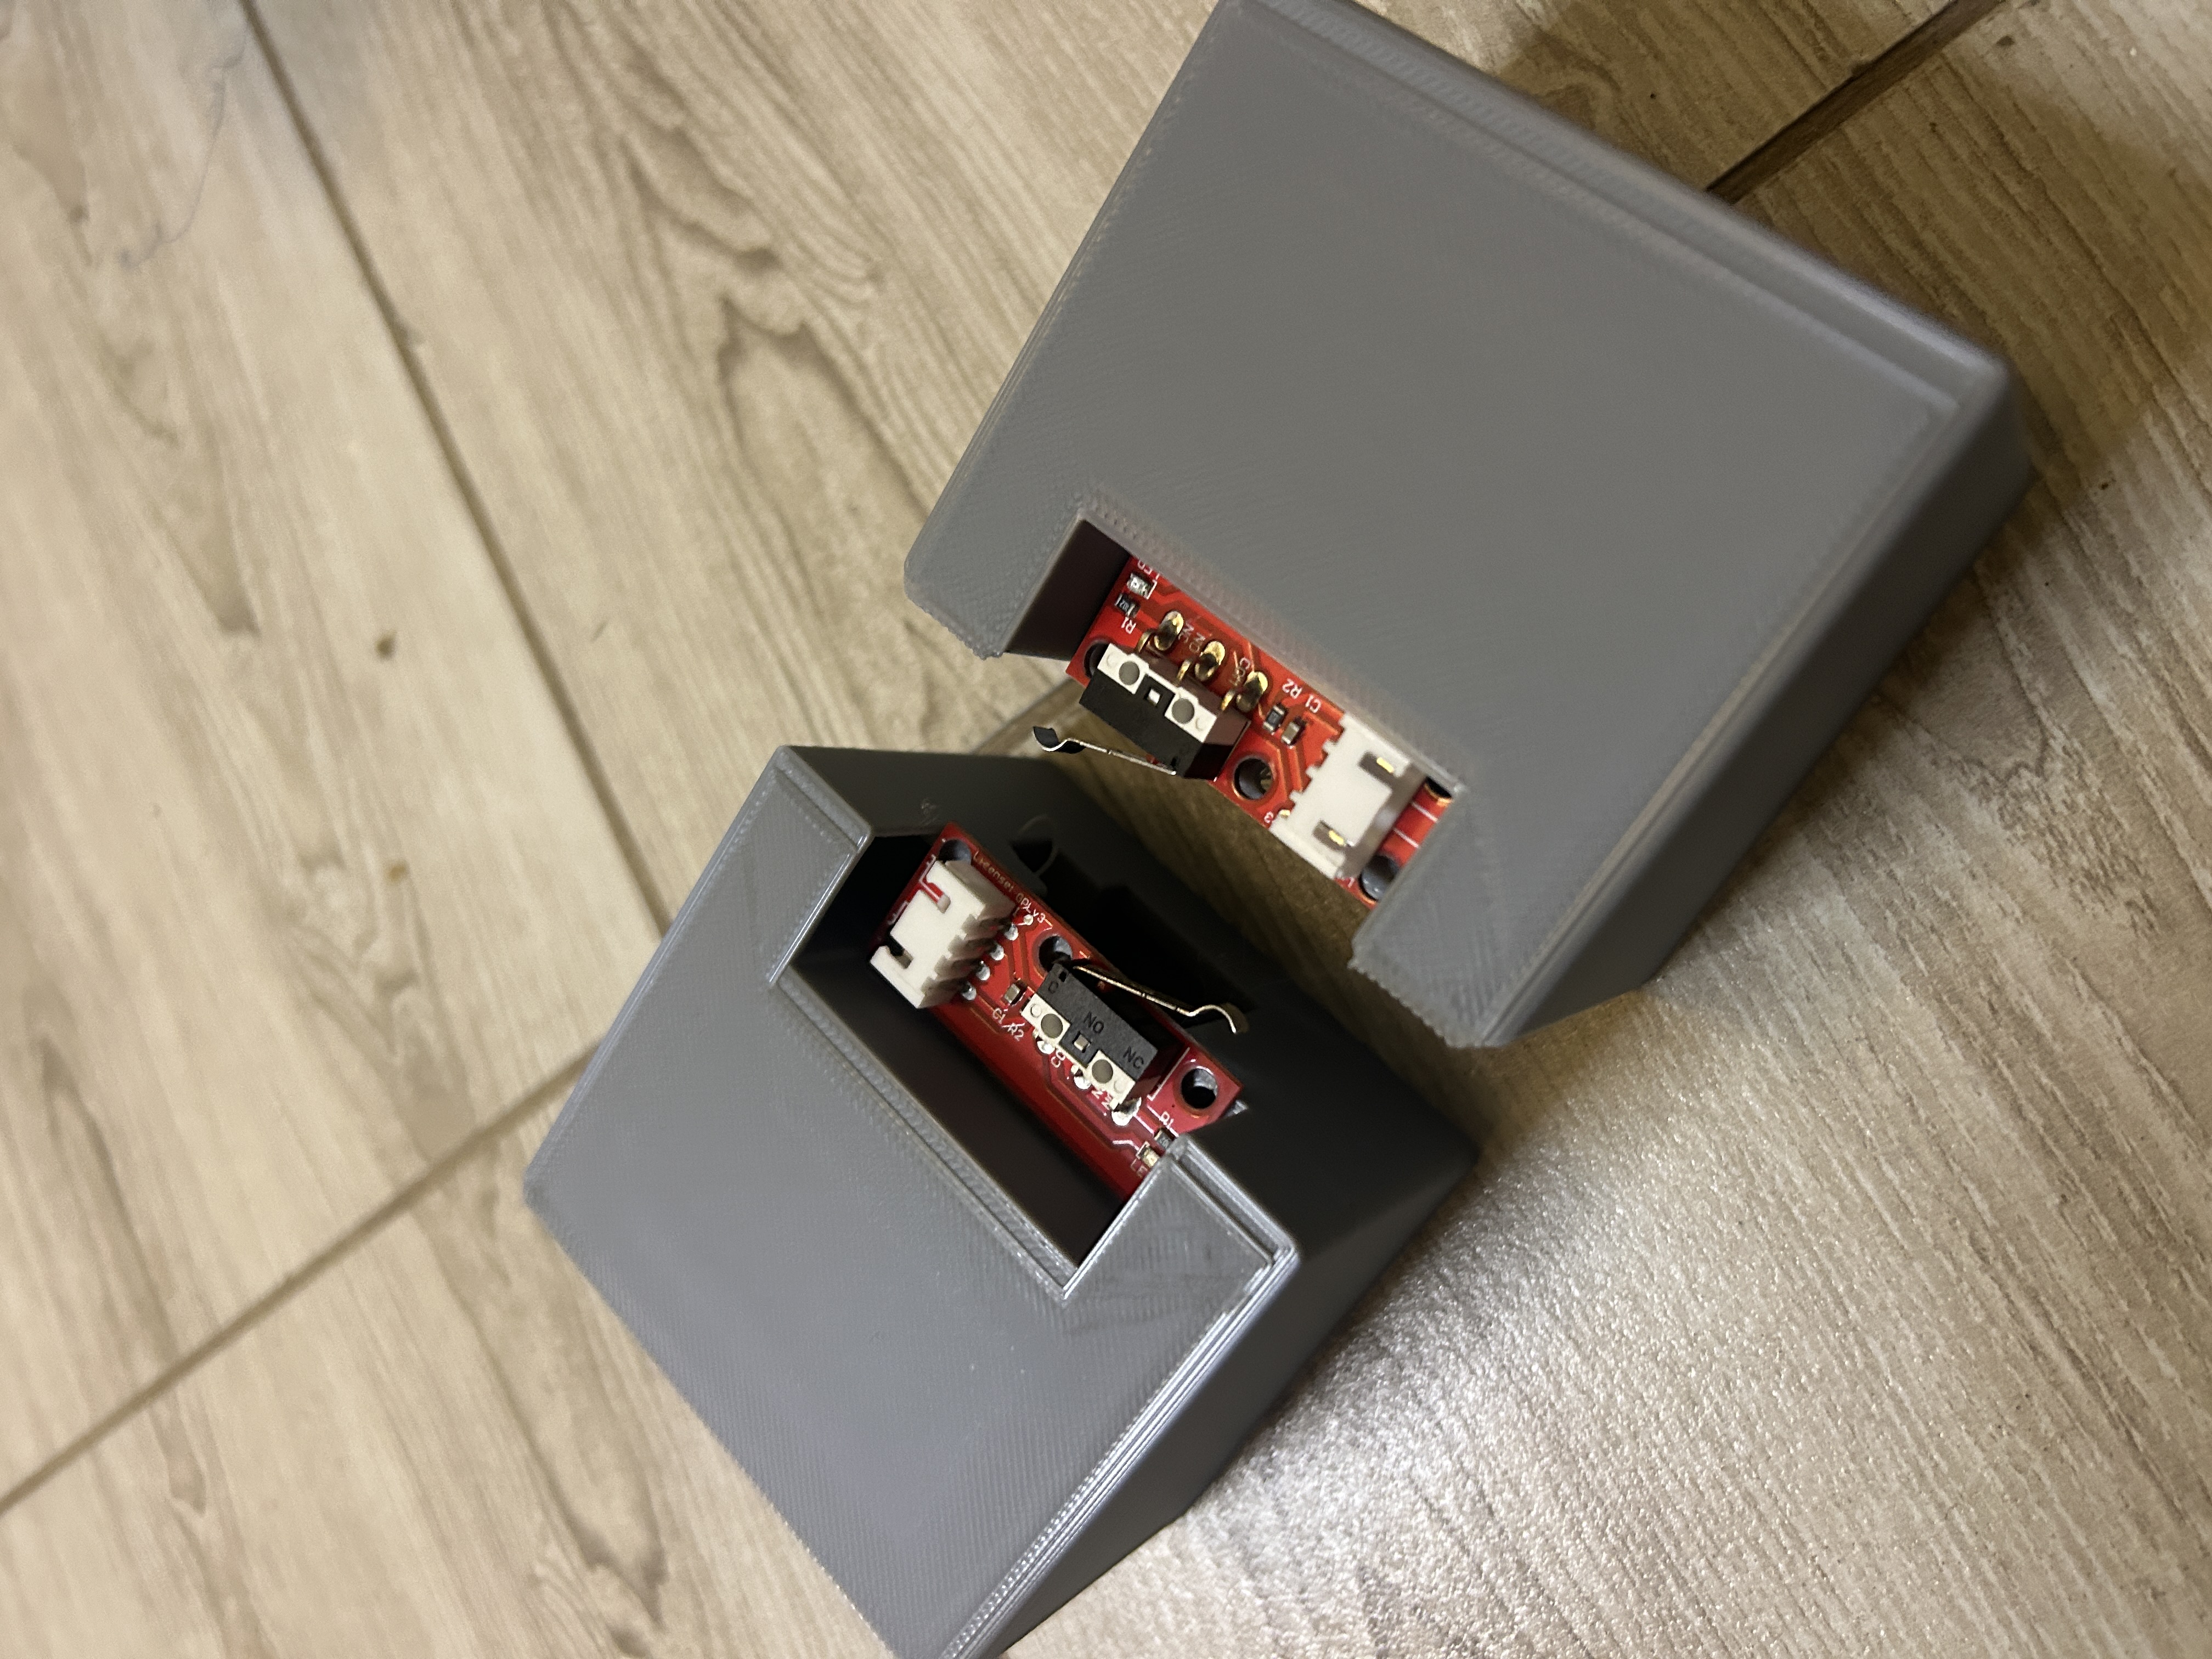
Wiring MakerBot Mechanical Limit Switches to an ESP32-C3 SuperMini
Two MakerBot-style Mechanical endstop switches each with 3-wire red/green/black, wired to an ESP32-C3 supermini Covers the power/ground/signal wiring, pull-up configurations, and firmware needed to read both switches reliably with proper debouncing.
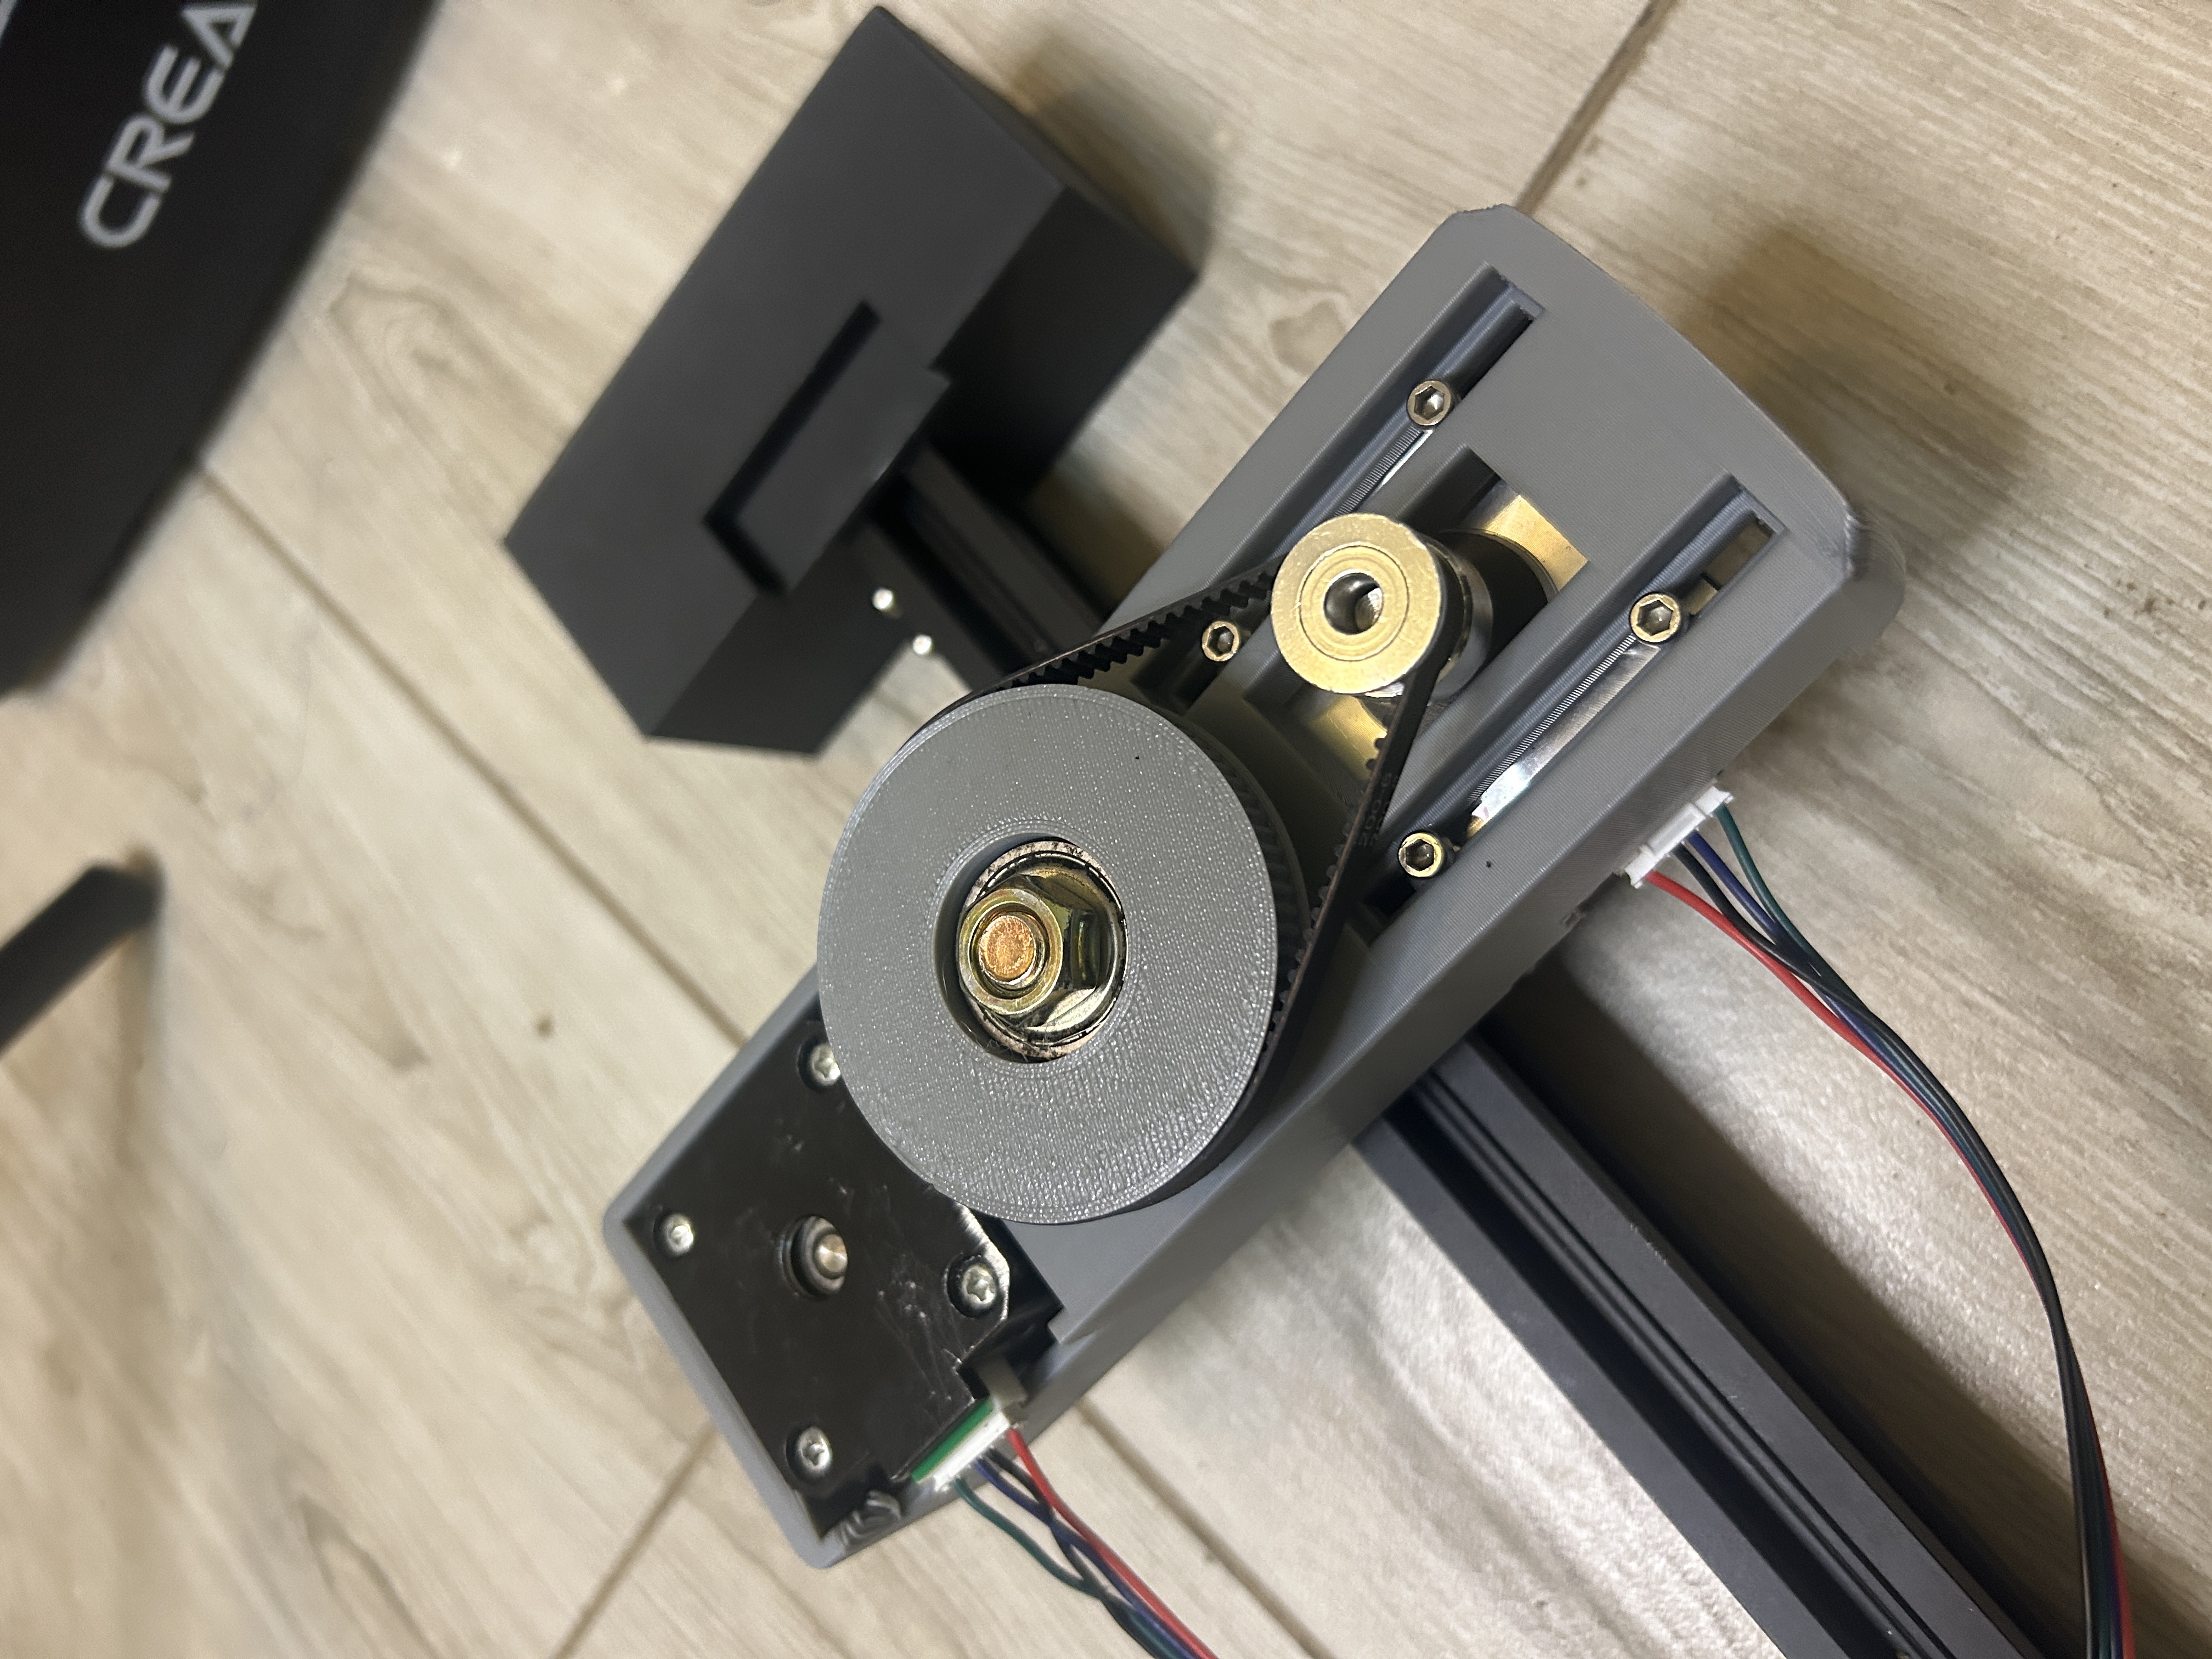
Building a motorized Linear Pan Rig with ESP-32 C3 Supermini, NEMA 17 and CNC shield.
A belt-driven linear rig with pan axis, built on 2020 aluminium v0-slot extrusion, GT2 Belts, dual NEMA 17 steppers, CNC Shield, and an ESP32 C3 Supermini
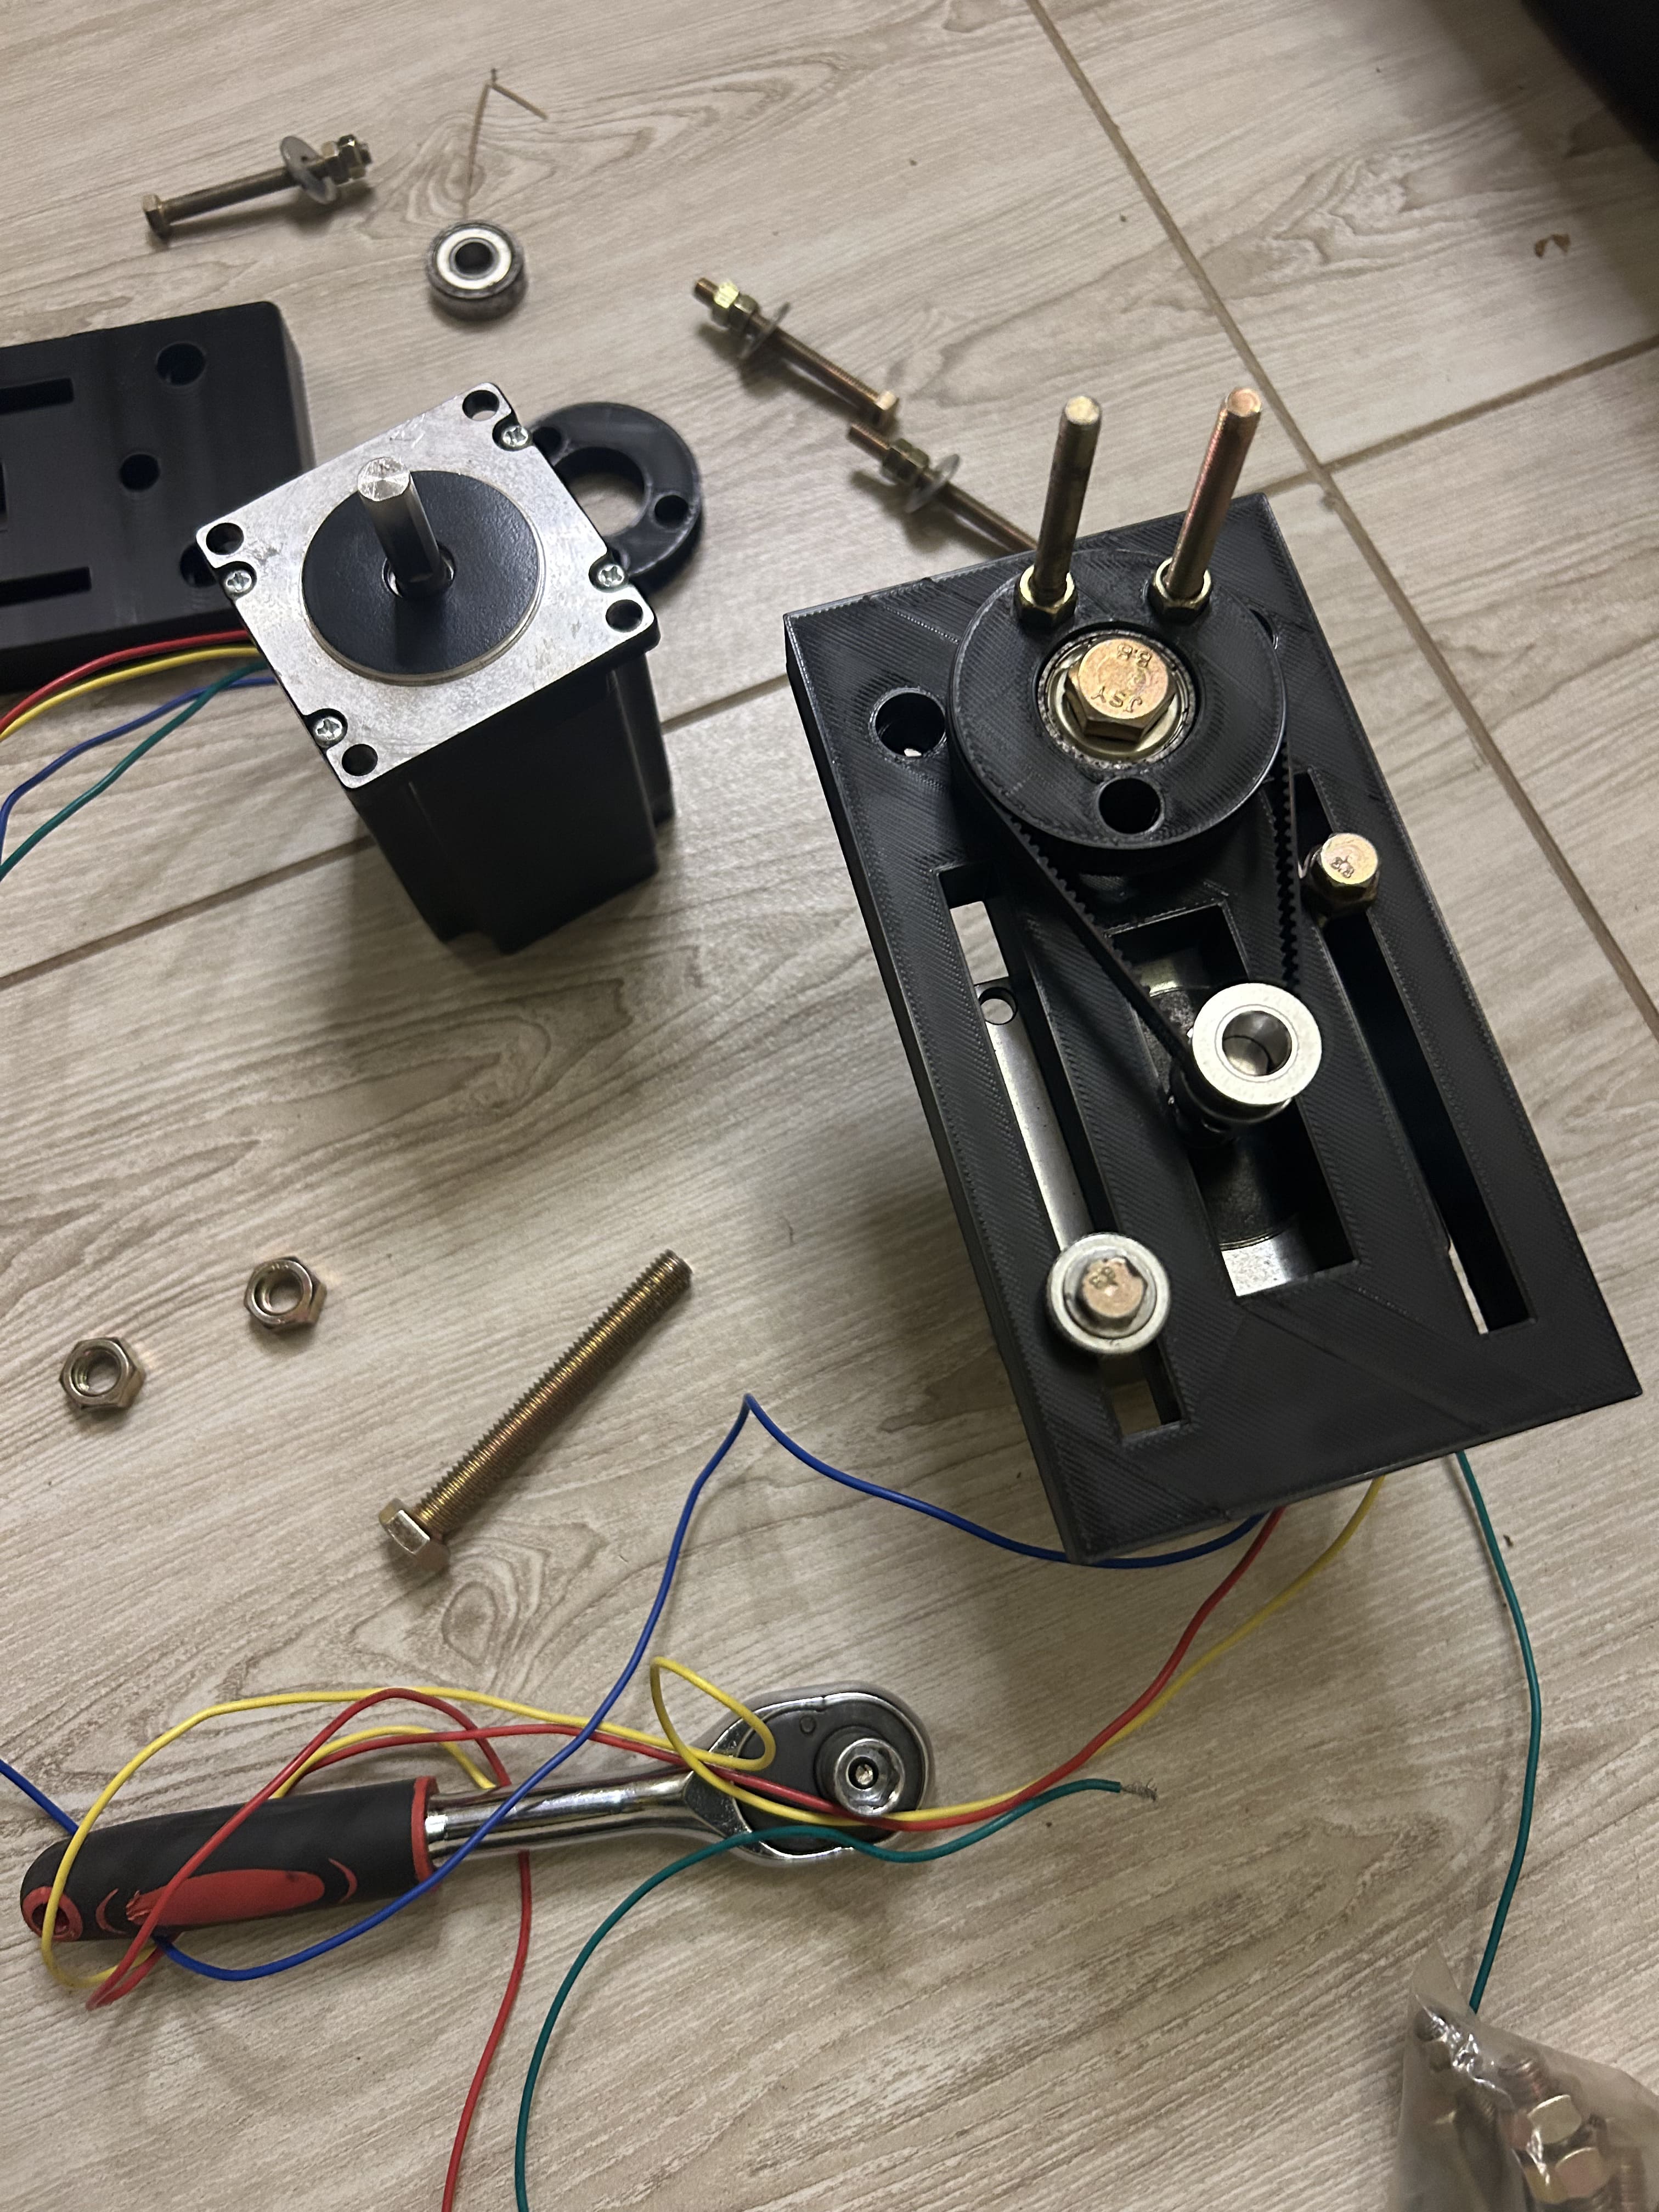
6-Axis Robot Arm . Joint 1 : Building the Belt Reduction Base Drive
The first joint of my 6-axis robot arm is done. NEMA 23-driven belt reduction stage using 3D-printed mounts, a 70-tooth pulley, GT2 belts, and a 608z bearing for the pivot. Here's what went together, what I got wrong, and the files if you want to build your own
From Microcontrollers to Cloud Dashboards
Every build runs on the same AI-assisted engineering loop: Claude Code drives implementation against custom Model Context Protocol (MCP) servers that expose real project context — device schemas, API contracts, deployment targets — while Laravel 13 turns that into a production-ready backend fast enough to keep pace with hardware iteration.
Featured Articles & Build Logs
View all →Articles coming soon.